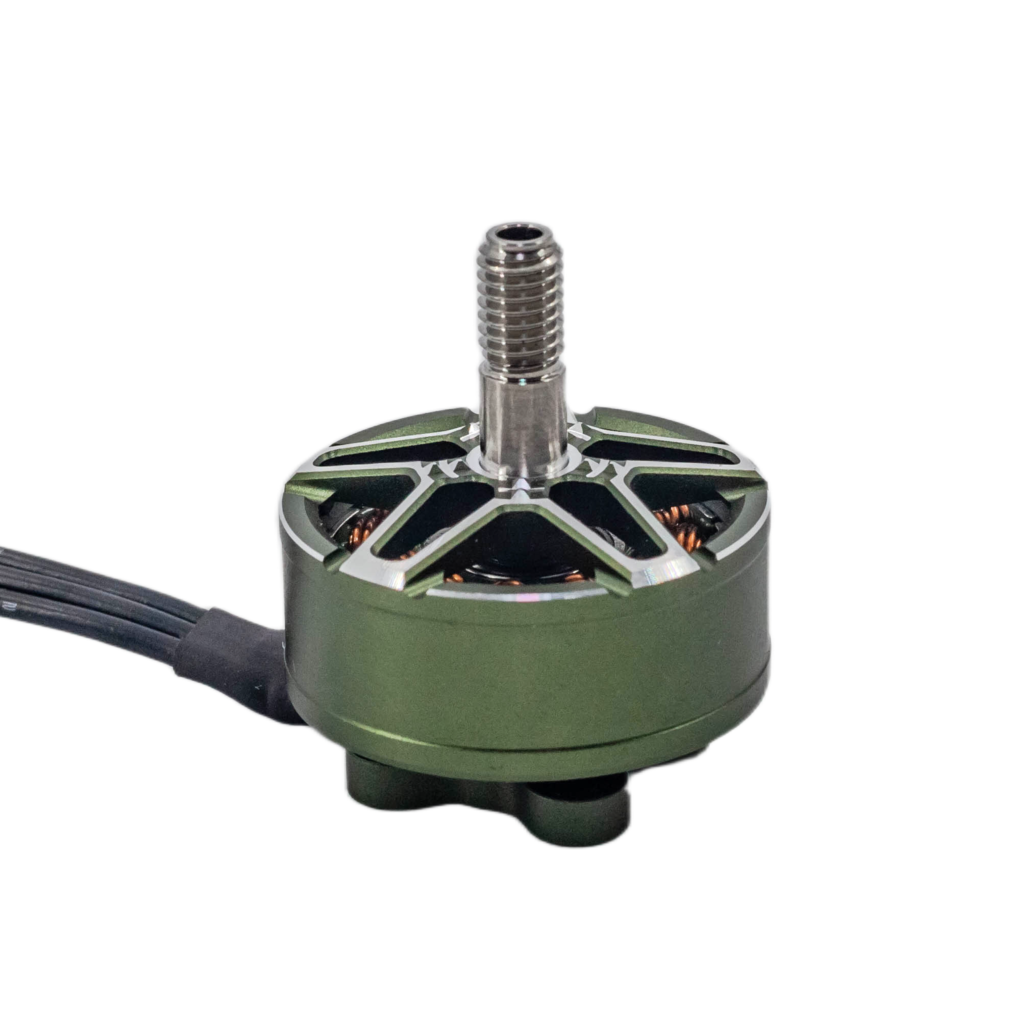
The uncomfortable conclusion is that the next generation of UAV power systems will not be won by the motor with the highest efficiency number.
It will be won by the system that wastes the least energy under the exact conditions in which the aircraft actually flies. That sounds obvious. It is also routinely ignored.
For years, UAV motor specifications have revolved around familiar numbers: efficiency, maximum thrust, power, weight, KV rating and sometimes power density. Those numbers are useful, but they become surprisingly misleading when separated from the propeller, ESC, battery voltage, payload and operating point.
A motor that reaches 95% efficiency on a test bench does not magically give the aircraft a 95% efficient propulsion system. That distinction is becoming more important as UAV power units move toward higher power density, higher voltage platforms, direct-drive architectures and more demanding environmental protection.
Efficiency Is No Longer a Motor-Only Problem. The most questionable number in many UAV power-system comparisons is the headline efficiency figure. A motor may be described as operating around 91% efficiency, while another is claimed to reach 92–95%. On paper, the second system wins. In an aircraft, that comparison is incomplete.
The actual electrical-to-thrust chain looks more like this: Battery → ESC → motor → propeller → airflow → aircraft thrust. Every stage introduces losses. Copper resistance creates heat in the windings. Switching losses appear in the ESC. Connectors and wiring add additional resistance. The battery voltage falls under load because of internal resistance. The propeller converts shaft power into useful thrust with its own aerodynamic losses.
And the operating point keeps moving. A multirotor climbing with a heavy payload is not operating at the same point as one cruising at partial throttle. A delivery UAV hovering at maximum takeoff weight is not experiencing the same thermal conditions as an empty aircraft. A high-speed FPV platform can spend a completely different proportion of its flight envelope at high current than a mapping aircraft.
So the useful engineering question is not simply: “What is the motor’s peak efficiency?” It is: “How efficiently does the complete propulsion system convert stored battery energy into the required aircraft performance across the mission profile?” That is a much harder number to publish. It is also the one engineers actually need.
Higher Power Density Does Not Make the Heat Disappear. Power density is another metric that looks excellent until the thermal bill arrives. Shrinking a motor while maintaining or increasing its output can reduce propulsion-system mass. But the electrical and thermal consequences do not disappear just because the housing gets smaller. Higher current means higher resistive losses in the winding and conductors. Those losses scale approximately with I²R, which is why current becomes such a nasty constraint as power rises. The pressure then spreads outward from the motor.
The ESC needs sufficient current capacity and thermal margin. Connectors need to handle the electrical load without becoming localized heating points. Wiring resistance becomes more consequential. Battery internal resistance becomes part of the thermal problem. Bearings and mechanical components must tolerate higher loads and temperatures. The airframe must eventually get rid of all the heat that the electrical system cannot convert into useful mechanical work.
Look, this is where the “smaller, lighter, more powerful” narrative starts to break down. A higher-power-density motor can be a genuine engineering improvement, but only if the rest of the propulsion architecture can support it. Otherwise, the designer has not removed the bottleneck. The designer has simply moved it.
Higher Voltage Is a System-Level Tradeoff. This helps explain why higher-voltage architectures are becoming increasingly relevant for demanding UAVs. For a given electrical power, increasing voltage allows the required current to fall: P = V × I
Lower current can reduce resistive losses in conductors and other components, assuming the rest of the system is designed around the higher voltage.
But higher voltage creates its own engineering requirements. ESC voltage ratings, insulation, switching devices, connectors, battery configuration and protection become more demanding. The benefit is therefore not “high voltage is better” in isolation.
It is a question of where the entire aircraft’s electrical architecture sits on the voltage-current tradeoff. That becomes particularly significant for heavy-lift UAVs, where the power requirement can grow rapidly with aircraft mass, payload and operating conditions. The motor is only one part of the equation.
Direct Drive Makes More Sense as the Aircraft Gets Heavier. Direct-drive propulsion is another area where broad market claims deserve caution. One industry source claims that more than 30% of 100-kg-class logistics UAVs now use direct-drive motors. Without the underlying sample size, geographic coverage, manufacturer population or methodology, that figure should be treated as an industry claim rather than an established market statistic.
The engineering trend itself is easier to understand. Direct drive removes a mechanical transmission stage between the motor and propeller. That can eliminate gearbox-related mass, mechanical losses, backlash and additional maintenance requirements. But direct drive does not eliminate the fundamental torque requirement.
Large propellers operating at relatively low rotational speeds demand substantial torque. The motor therefore needs an electromagnetic and mechanical architecture capable of producing that torque continuously while managing heat, structural loads and rotor dynamics. That can push the motor toward a larger diameter and different magnetic and winding design.
So direct drive is not simply a lighter alternative to geared propulsion. It is a different optimization. For large UAVs, the trade can become attractive because the motor, propeller and airframe can be designed around a low-speed/high-torque operating point rather than forcing a high-speed motor through a reduction stage. But whether that architecture makes sense still depends on the aircraft mission.
IP65 or IP67 Is Not a Complete Power-System Specification. Environmental protection is also moving higher up the UAV propulsion checklist. IP65 and IP67 are increasingly referenced in industrial UAV discussions, particularly where aircraft operate around rain, dust, agricultural chemicals or other harsh environments.
But there is a technical trap here. What exactly is rated IP65 or IP67? The motor housing? The ESC? The combined power unit? The connector assembly? Or the entire aircraft? These are not interchangeable claims.
A motor enclosure can have a particular ingress-protection rating while the electrical connector, cable interface or ESC enclosure has a completely different exposure profile. A UAV that claims a protected motor therefore does not automatically have an IP67-rated propulsion system.
And ingress protection is not a synonym for unlimited environmental durability. Water temperature, pressure, chemical exposure, condensation, salt, mud and repeated thermal cycling can produce failure mechanisms that a simple IP rating does not fully describe. This is one reason standardized test conditions matter more as industrial UAV deployment expands.
The Standards Are Becoming More Specific — But Not Necessarily in the Way Headlines Suggest. There is a useful 2026 development here, but it needs to be described accurately. T/CASME 2168—2026, titled Technical Specification for Propeller Motors of Unmanned Aerial Vehicles, was published in 2026 and took effect on June 28, 2026. It specifies general requirements, technical requirements, test methods, inspection rules, marking, packaging, transportation and storage for UAV propeller motors. It is a group standard, not a national GB standard.
That distinction matters. Claims that China introduced a completely new “national UAV motor standard” in 2026 are misleading if they are referring to T/CASME 2168—2026.
China’s existing GB/T 39567-2020, General Specification for Brushless Servo Motor Systems for Multi-Rotor Unmanned Aircraft, remains listed as a current recommended national standard. It was published on December 14, 2020 and implemented on July 1, 2021.
The older standard is also broader than a motor-only specification: it covers the brushless servo motor system, including the permanent-magnet brushless servo motor and its drive, along with communication interfaces, operating conditions, technical requirements, test methods, inspection and delivery preparation.
Wait, let me double-check the terminology here: that is precisely why calling every new 2026 motor requirement a “new national standard” creates confusion. The document type, scope and legal status matter.
Standardization is useful because it can make manufacturer claims more comparable. It does not automatically make every motor conforming to a particular document equivalent in real-world UAV performance.
“Domestic Supply Chain” Is Still Too Broad a Claim. Another frequently repeated industry statistic is that domestic UAV power-system components now account for more than 85% of the market, alongside claims that permanent magnets, control chips and winding materials are essentially self-controlled. Those statements require considerably more evidence than a percentage.
A supply chain is not “domestically controlled” simply because the final motor is manufactured domestically. A meaningful assessment would need to separate at least the motor, magnets, electrical steel, copper wire, bearings, sensors, power semiconductors, gate drivers, control electronics, connectors and manufacturing equipment. It would also need to distinguish final assembly from the origin of critical materials and semiconductor technology.
A motor manufacturer can therefore have a highly localized assembly chain while retaining external dependencies in specific materials or electronic components. The more interesting question for 2026 is not whether UAV power systems are becoming more localized. It is which dependencies remain difficult to replace, and which ones have actually reached production-scale substitution. That is where a real supply-chain analysis begins.
The Power Unit Is Becoming a Mission-Level Component. The direction of travel is clear even if several industry statistics are not yet sufficiently documented. UAV propulsion development is moving toward higher efficiency, greater power density, better environmental protection, higher-voltage electrical architectures and tighter integration between motor, ESC, propeller and battery. But none of those developments should be evaluated in isolation.
A 95% motor can be a poor propulsion choice if it operates outside its efficient region during the mission. A lightweight motor can create a thermal problem elsewhere. A high-voltage architecture can reduce current while increasing insulation and switching requirements. A direct-drive system can eliminate a gearbox while demanding more motor torque and structural capacity. An IP-rated enclosure can protect one component while leaving another exposed.
That is the real blind spot in the power-unit discussion. The industry’s next performance metric probably will not be another impressive number printed on a motor datasheet. It will be how much useful aircraft work the entire propulsion system delivers per unit of stored energy, under a defined payload, voltage, altitude, temperature, flight profile and duration.
That number is considerably harder to fake. And considerably harder to engineer.